
Federico Sarrocco
Autonomy Software Engineer
Pushing the boundaries of autonomous systems through innovative solutions in robotics, AI, and racing technology.
PoliMove Experience
- ▹Developed advanced software for autonomous racing vehicles EAV-24 (Super Formula)
- ▹Focused on improving trajectory planning for head-to-head racing scenarios
- ▹Worked on the estimate of overtake zone on road-courses
Dynamis PRC - Formula Student Team
- ▹Led a team of 12 engineers in developing software and hardware systems for an autonomous race car
- ▹Oversaw the development of perception, localization, mapping, trajectory planning, and control systems
- ▹Coordinated cross-functional efforts to ensure peak performance in competitive racing conditions
- ▹Gained hands-on experience in autonomous vehicle technology within a high-pressure, competitive environment

Argo Robot Co-Founder
Developing innovative home companion robots for entertainment, education, and security.
Technical Expertise
Latest Blog Posts
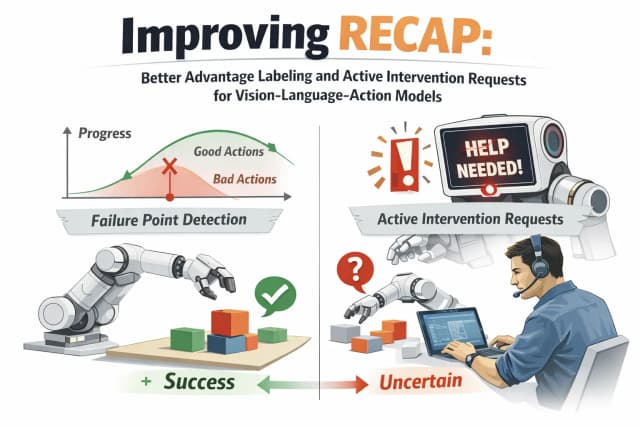
Improving RECAP: Better Advantage Labeling and Active Intervention Requests for VLA Models
Feb 12, 2026
We propose two improvements to RECAP: failure point detection for precise advantage labeling in failed trajectories, and active intervention requests that let the robot ask for help when uncertain - shifting from constant human monitoring to efficient collaboration.
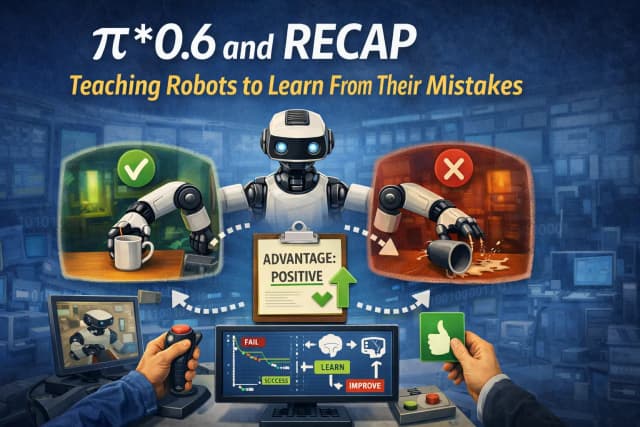
π*0.6 and RECAP: Teaching Robots to Learn From Their Mistakes
Jan 18, 2026
A deep dive into Physical Intelligence's π*0.6 model and the RECAP method - an elegant technique that enables Vision-Language-Action models to improve through reinforcement learning without requiring policy gradients.
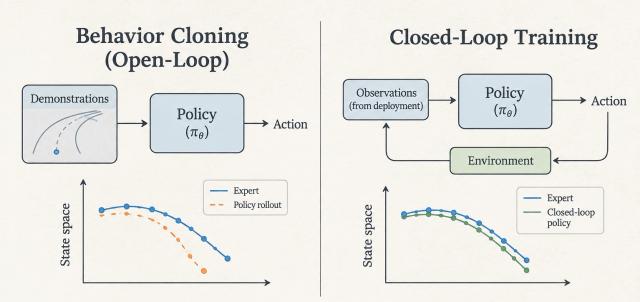
Beyond Behavior Cloning: Closed-Loop Training for Embodied Autonomy
Jan 11, 2026
Why policies trained on static demonstrations fail in the real world, and how closed-loop training — from DAgger to world-model-based RL — is reshaping the way we build autonomous robots.
The Future of Robotics: A Vision of Intelligent, Adaptable Machines
Mar 31, 2025
Exploring the next frontier in robotics, where intelligent, adaptable machines transform our lives through flexibility, autonomy, and the fusion of AI with physicality.

Speed Profile Generation: An Easy and Fast Method for Motion Planning
Feb 21, 2025
Discover a robust three-step algorithm for generating vehicle speed profiles that guarantees adherence to physical constraints while remaining computationally efficient. Perfect for robotics and autonomous systems!
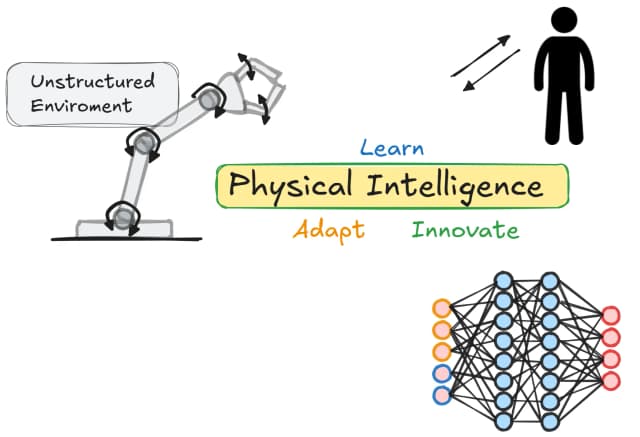
Physical Intelligence in Robotics: Bridging AI and the Physical World
Feb 7, 2025
An in-depth exploration of Physical Intelligence in robotics, focusing on the integration of AI with physical interaction and adaptability.
Making quadrupeds Learning to walk: Step-by-Step Guide
Feb 4, 2025
Learn how to train a quadruped robot to walk using reinforcement learning, from defining actions and observations to designing rewards and transitioning from simulation to reality.

Footsteps Planning: Step-by-Step Guide
Jan 26, 2025
A comprehensive guide to footstep planning for bipeds and quadrupeds, covering 2D and 3D foot trajectories, ZMP generation, and CoM trajectory computation.

Wake-Word Detection for your AI robot: A Step-by-Step Guide
Jan 8, 2025
Learn how to build a wake-word detection system for your devices, exploiting NLP and AI. Understand the key concepts, training process and its application in robotics.
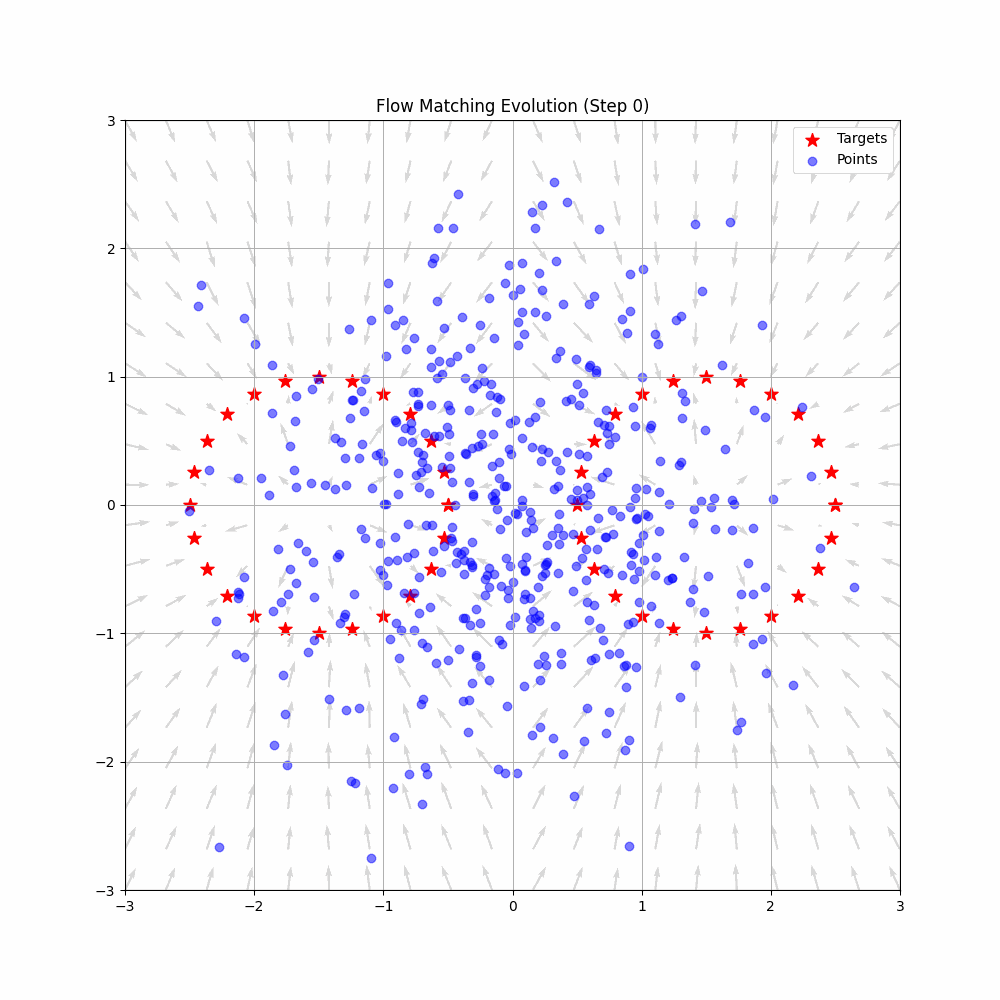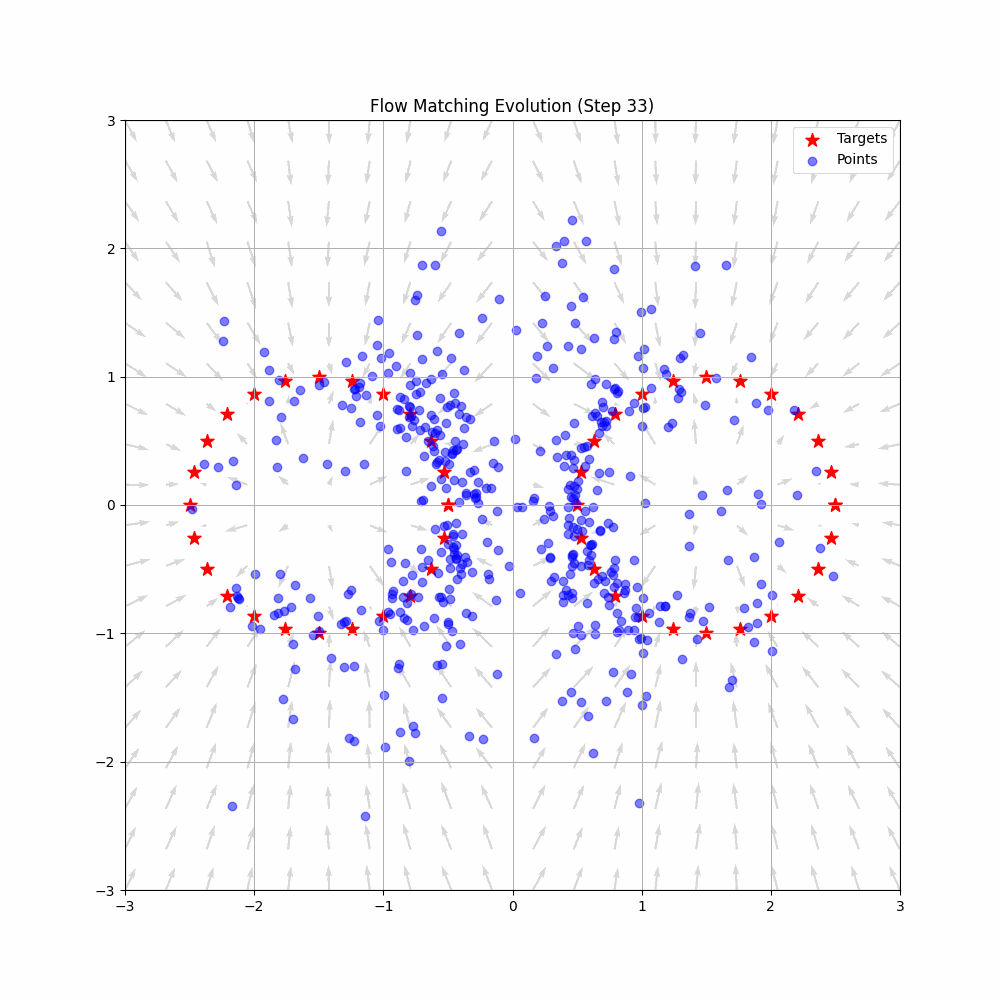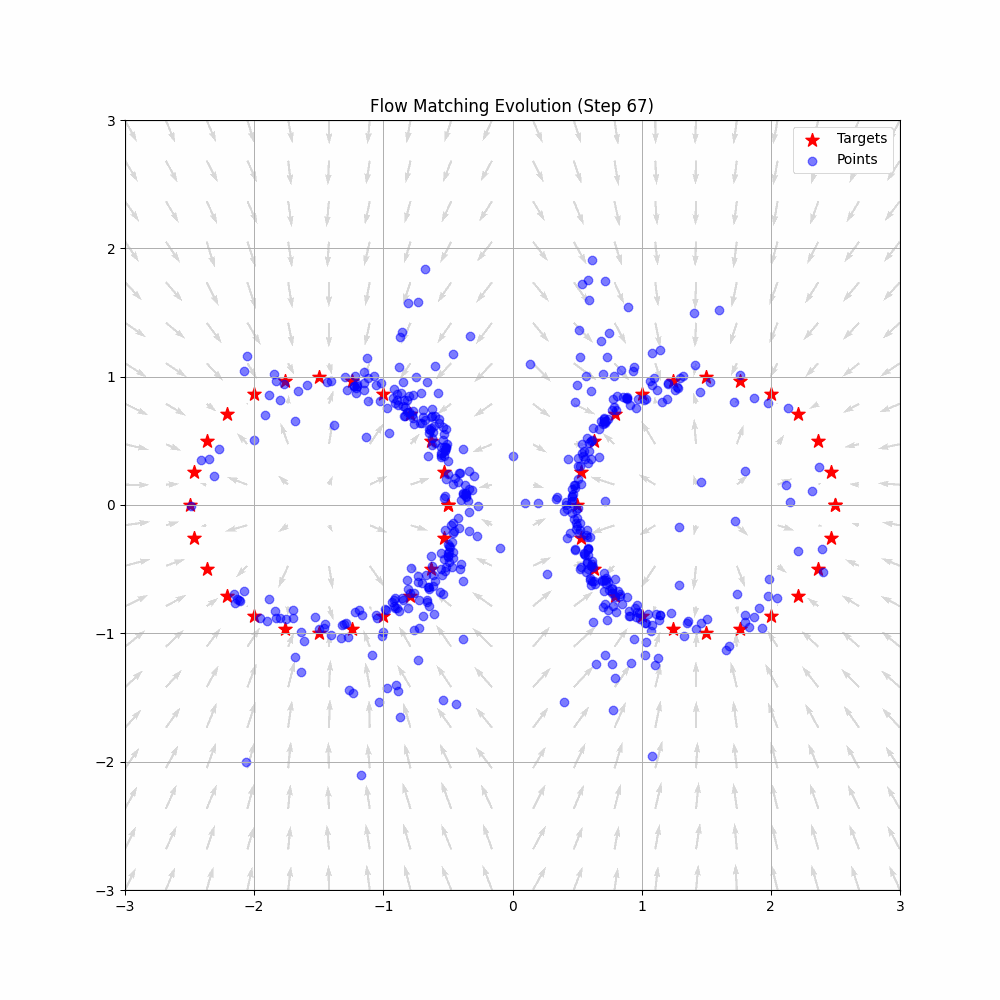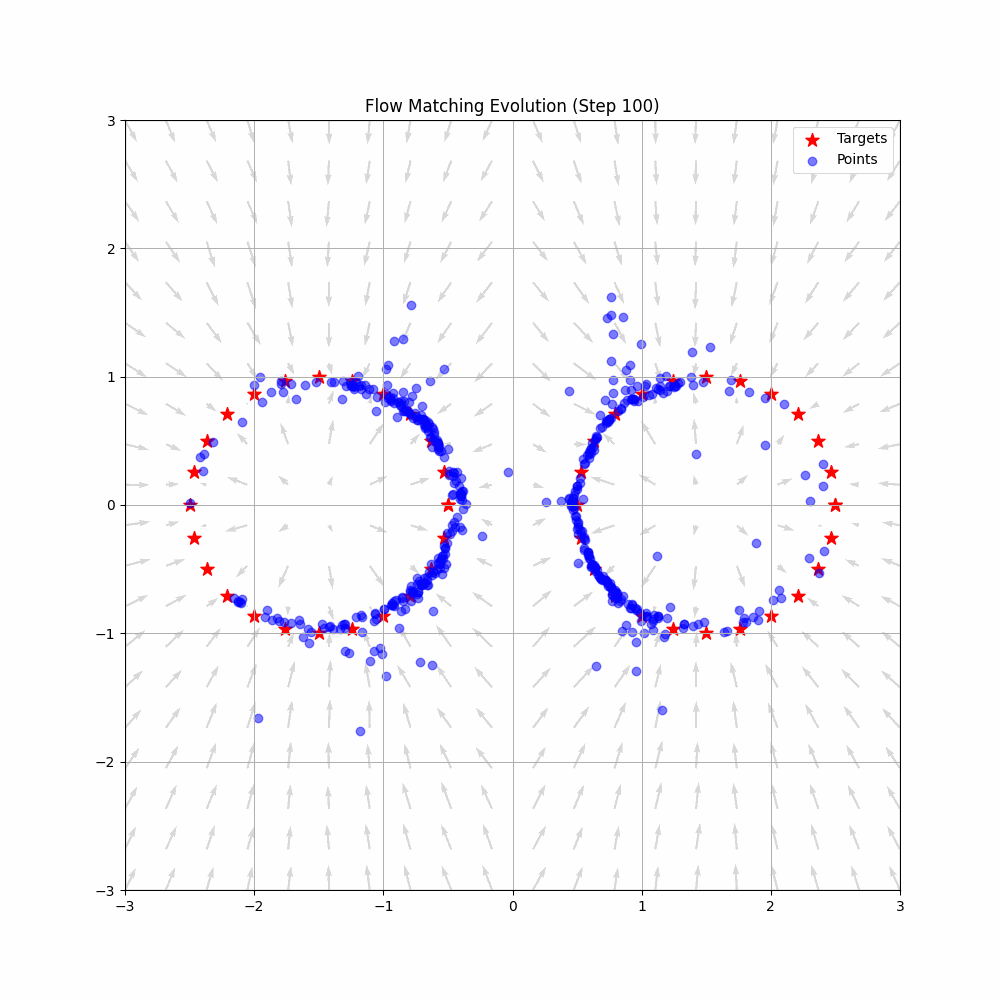
Flow Matching Explained: From Noise to Robot Actions
Nov 8, 2024
Learn how flow matching generates continuous data, such as robot actions, by denoising samples drawn from a simple noise distribution. Understand the key concepts, training process, and application in robotics.
Graph SLAM: From Theory to Implementation
Oct 26, 2024
A comprehensive guide to understanding and implementing Graph SLAM, covering theoretical foundations, mathematical principles, and practical implementation with real-world examples.
Mastering Quadratic Programming: From Theory to Practice
Oct 20, 2024
A deep dive into Quadratic Programming, covering theory, applications, and solution methods with practical examples.
Line Search Methods in Unconstrained Optimization
Oct 15, 2024
An exploration of line search methods for solving unconstrained optimization problems, including their implementation and convergence properties.
Integrating ROS 2 with Custom C++ Libraries for Advanced Robot Functionality
Sep 22, 2024
A comprehensive guide to seamlessly integrating custom C++ libraries with ROS 2 for enhanced robot capabilities.

My Journey in Formula Student: From Developer to Team Leader
Jul 15, 2024
Five years at Dynamis PRC, Politecnico di Milano's Formula Student team: perception and path planning development, then leading the 12-engineer driverless department to 1st place in the FSG Autocross.

PoliMove and A2RL: Head-to-Head Autonomous Racing
Jun 21, 2024
Inside PoliMove's A2RL campaign: trajectory planning for multi-agent head-to-head racing, overtake-zone estimation, and vehicle dynamics modeling.

Multi Path Trajectory Tracking in Dynamic Traffic Environment
Jun 19, 2024
Exploring an optimal control system using Model Predictive Control for autonomous vehicle navigation in dynamic traffic.
Unit Testing Robotic Software Components: Best Practices in C++
Apr 22, 2024
A comprehensive guide to writing effective unit tests for robotic software components, with practical examples and best practices in C++.
Concurrency in C++: Threading and Synchronization for Robotic Systems
Feb 25, 2024
Dive deep into the world of concurrent programming in C++ for robotics. Explore threading, synchronization techniques, and strategies for creating efficient multi-threaded robotic systems. Learn how to leverage mutexes, condition variables, and atomic operations to build responsive and robust robots.
Memory Management in C++: Best Practices and Common Pitfalls
Feb 20, 2024
Explore the intricacies of memory management in C++ with a focus on robotics applications. Learn about RAII, smart pointers, and best practices to write efficient and robust code while avoiding common memory-related pitfalls.
Mastering Modern C++: Essential Features in C++17 and C++20
Feb 15, 2024
Explore key features introduced in C++17 and C++20 that are particularly relevant for robotics development. Learn about structured bindings, concepts, ranges, coroutines, and more to enhance your C++ coding in robotics projects.
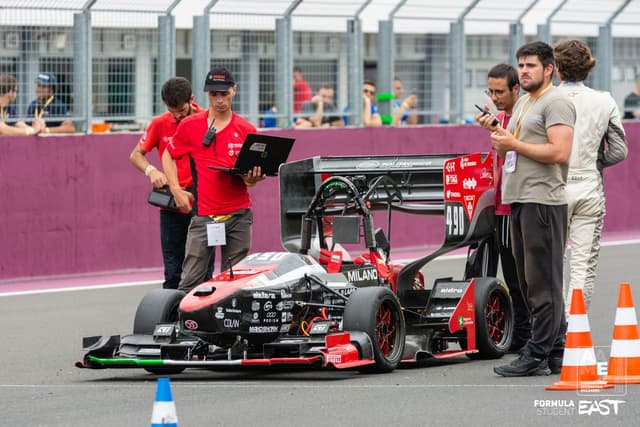
Autonomous Functionality in Formula Student Dynamis PRC
Jan 19, 2024
An overview of the autonomous driving modules in the Dynamis PRC Formula Student car.